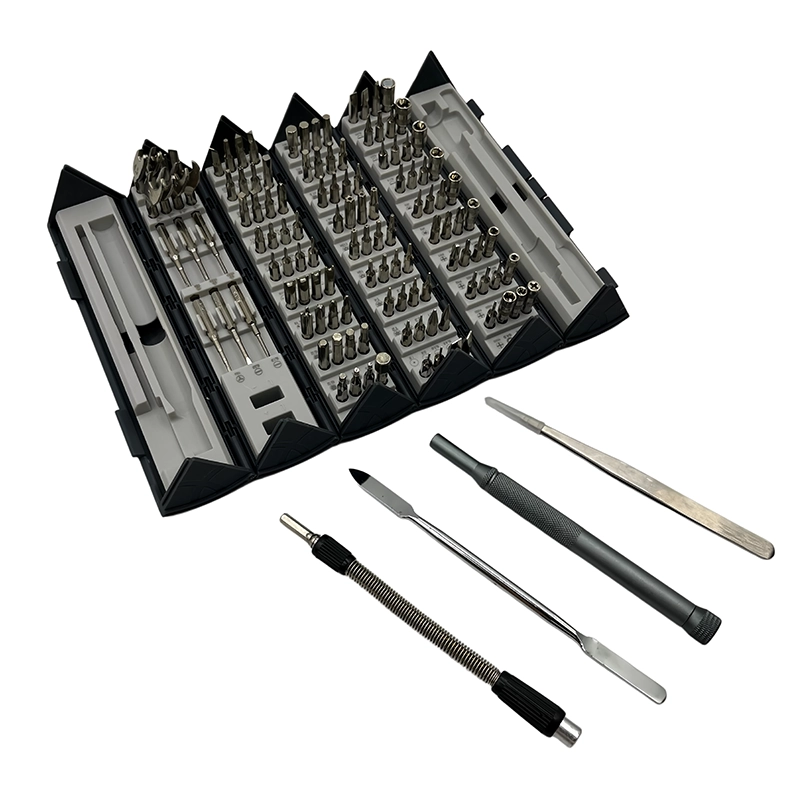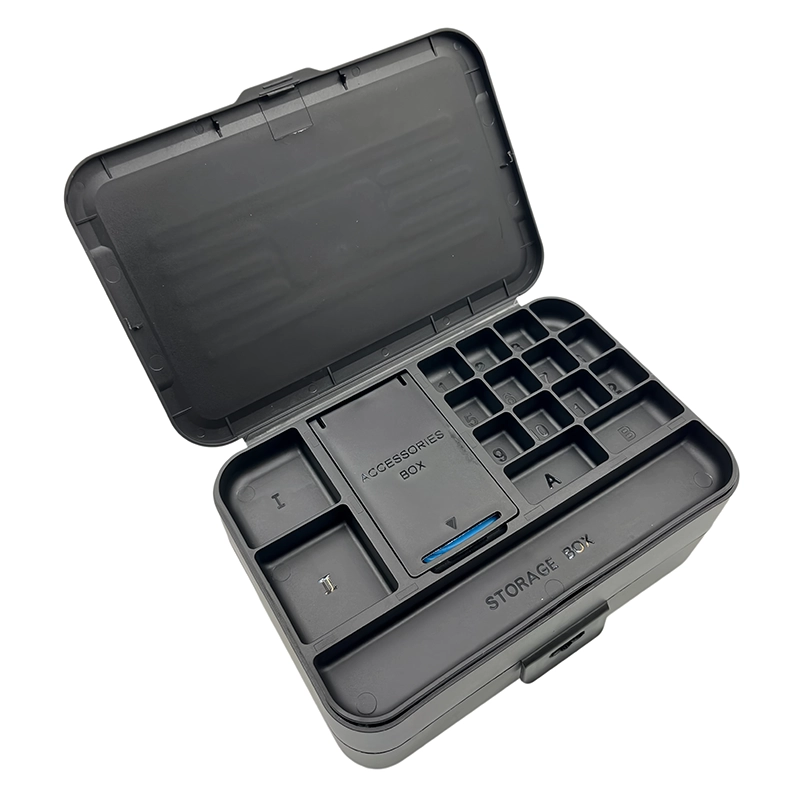
For smart pet feeder motor and sensor service, separate food-contact cleaning from motor and electronics disassembly. Verify power removal, food residue, motor preload, sensor alignment, cable routing, and washable-part boundaries before turning. Stop when moisture reaches electronics, a battery is damaged, or the gear preload is undocumented. Keep every screw mapped by position and follow the exact product or assembly instructions.
smart pet feeder motor and sensor service manual screwdriver workflow
smart pet feeder motor and sensor service manual screwdriver workflow is the controlled method used to identify the fastener and joint, choose a fully fitting manual bit, preserve removed-hardware positions, recognize a stop condition, and verify the restored assembly without substituting extra leverage for product-specific instructions.
What must be known before smart pet feeder motor and sensor service?
Smart feeders combine food-contact bowls or hoppers with motors, gears, sensors, batteries, and control electronics. Crumbs and oils can enter screw recesses, while some modules must stay dry. The first planning decision for smart pet feeder motor and sensor service is therefore not the size of the case or the advertised piece count. It is the boundary of the job: which assembly may be opened, which energy sources must be isolated, what information must be preserved, and which condition requires escalation. Read the current maker instructions for the exact model, because a nearby model can use another screw length, cable path, seal, or release order even when the exterior looks familiar.
Write the question “Which manual screwdriver workflow protects a smart pet feeder motor, bowl sensor, battery door, and food-contact areas?” at the top of the work record for smart pet feeder motor and sensor service. That wording keeps the task connected to a customer decision instead of a generic claim about tools. Record device or assembly identity, revision, visible condition, power state, fastener map, and the expected completion check. A bench photograph is useful only when it is labeled and linked to the correct unit; it should complement, not replace, a position map and a count of loose components.
What failure pattern should stop smart pet feeder motor and sensor service?
Food residue can prevent full bit seating, and a misaligned gear or sensor can overfeed, jam, or fail even when the housing closes. The explicit stop condition for smart pet feeder motor and sensor service is: moisture reaches electronics, a battery is damaged, or the gear preload is undocumented. A stop is a quality control, not an incomplete repair. Preserve the evidence by leaving the fastener and surrounding parts unchanged, note the direction and stage at which the condition appeared, quarantine damaged bits or unknown screws, and seek the maker’s procedure or an authorized decision. Repeated attempts erase geometry, mix wear patterns, and can turn an identifiable mismatch into an extraction problem.
Distinguish symptom, observation, and cause when reporting a problem in smart pet feeder motor and sensor service. “The screw did not move” is an observation; corrosion, adhesive, wrong profile, cross-threading, hidden retention, and an incorrect service assumption are different hypotheses. Record the bit identity, seating depth, applied method, work support, and visible condition without claiming a root cause that was not demonstrated. This separation gives an OEM, repair lead, or supplier enough information to decide whether the next action involves another tool, another process, or no further disassembly.
Which joint and tool factors control smart pet feeder motor and sensor service?
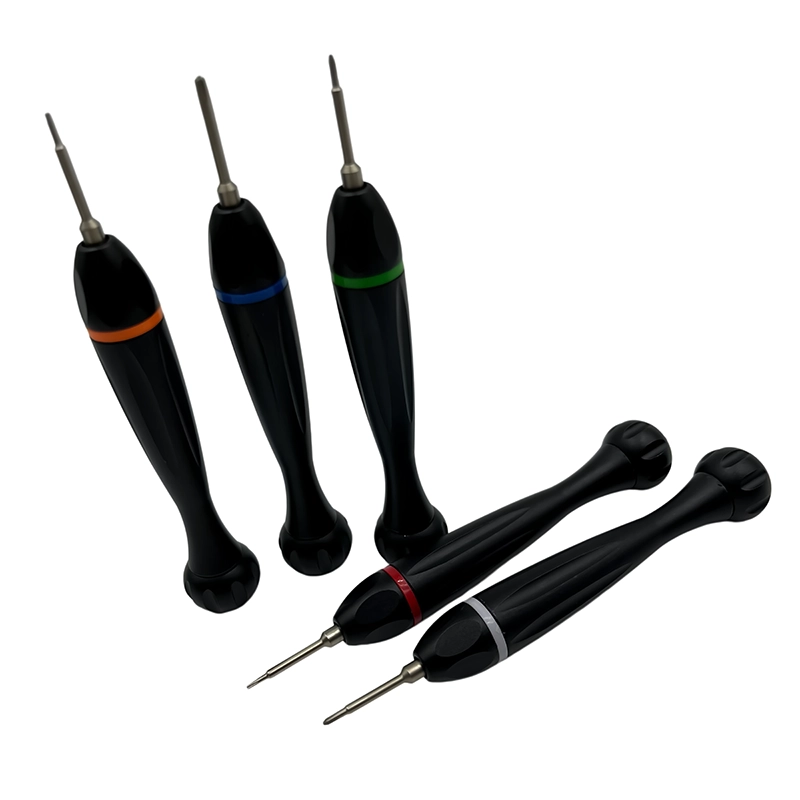
Compatible cleaning, motor and gear position, sensor brackets, battery safety, gasket placement, plastic-boss condition, and separation of washable and electronic parts govern tool handling. In smart pet feeder motor and sensor service, these factors interact. A correct profile can still fail when a worn bit sits shallowly, a long shaft is tilted, or a high-leverage handle conceals the first sign of binding. Conversely, a compact handle cannot rescue a mismatched recess. Inspect both the bit and fastener under adequate light, clean only by an approved method, seat the bit without torque, and reject rocking, bottoming, or contact with adjacent surfaces before applying hand force.
Manual feedback is valuable during smart pet feeder motor and sensor service, but it is not a torque measurement or proof of clamp load. Friction, coating, reuse, contamination, plastic relaxation, washer condition, and operator posture can all change perceived resistance. Use the specified tightening method whenever a maker or engineering drawing provides one. Where no value is published, restore the known hardware to its mapped location and documented seated condition; do not invent a universal “finger-tight” number or claim that one handle setting suits every material.
Which options should buyers compare for smart pet feeder motor and sensor service?
For smart pet feeder motor and sensor service, compare the first option “Food-zone hand tools,” used for Approved removable bowls and guards, with “Precision electronics set,” used for Motor, sensor, and control housing. The first carries this limitation: Must follow cleaning compatibility. The second carries this one: Must remain dry and clean. A third reference, “General household driver,” is associated with Available for large outer screws and must be judged against the warning that Can contaminate food-contact areas. These are decision categories, not universal performance rankings.
A buyer checklist for smart pet feeder motor and sensor service should require the exact target fasteners, profile and size map, short and long access needs, holder runout or stability, handle leverage, visible bit labeling, case retention, replacement-bit availability, and sample acceptance method. Add power removal, food residue, motor preload, sensor alignment, cable routing, and washable-part boundaries to the application trial. Count only delivered pieces and verify every material or compatibility claim against the released SKU. A supplier sample should reproduce the intended task; turning an unrelated demonstration screw does not establish access, fit, control, durability, or safe use in the customer’s assembly.
How should smart pet feeder motor and sensor service be staged step by step?
Remove food and power, clean only removable approved parts, photograph gear and sensor positions, map housing screws by dry zone, contain debris, route cables, and test dispensing without an animal nearby. Treat that sequence as a set of gates for smart pet feeder motor and sensor service. At each gate, reconcile the screw count, verify that no wire, spring, seal, washer, or spacer has moved unexpectedly, and photograph only the details the next step could conceal. Use separate labeled zones for removed layers. If the assembly contains both plastic-forming and machine screws, keep them physically separated even when their heads accept the same bit, because thread identity belongs to the receiving feature rather than to the head profile.
Before closure in smart pet feeder motor and sensor service, reverse the removal map rather than relying on a pile of parts. Start each fastener by hand with the surfaces naturally aligned; a screw must not be used to drag a cover, board, bracket, or insert into position. Leave multiple screws loose until alignment and cable clearance are visible, then use the specified sequence. Finish with the functional, visual, electrical, sealing, or movement check relevant to the assembly and document any condition that differs from the original baseline.
How does a real example change the plan for smart pet feeder motor and sensor service?
For a jammed dispensing wheel, document its index and washers, remove only the approved motor cover, keep food debris away from the board, and run repeated empty cycles before refilling. This example makes smart pet feeder motor and sensor service concrete because it names the object, the information to preserve, and the check required before closure. A credible field example should not imply an unpublished test result or a customer endorsement. It should explain the observable condition and the reasoning path: identify the joint, select the matching tool, support the work, map removed items, watch for the stop condition, and confirm the assembly’s intended function after restoration.
If the example is repeated during a sample review for smart pet feeder motor and sensor service, use representative fasteners and access geometry from the intended product. Record whether each candidate bit seats fully, whether the holder remains straight, whether the case makes the correct bit easy to identify, and whether the operator can stop before damage. Repeatability means that the written method can be followed by another trained person and produces comparable observations; it does not justify a certification, service-life number, or compatibility claim beyond the evidence collected.
What should an OEM brief require for smart pet feeder motor and sensor service?
Pet-product service kits need cleanable labeled storage, plastic-safe hand control, dry-zone instructions, screw maps, and explicit food-contact boundaries. Convert that requirement into controlled fields for smart pet feeder motor and sensor service: target market and user, representative devices or fasteners, bit map, materials tied to the released SKU, handle and holder requirements, accessory list, case layout, markings, packaging languages, sample method, acceptance criteria, order quantity, and revision control. Ask the supplier to identify assumptions and exclusions. A private-label color or logo should be approved only after the working platform and product contents have been frozen.
Catalog evidence for this smart pet feeder motor and sensor service guide is limited to the current XOENAEN record for the 128-in-1 manual screwdriver set. That record establishes that the named platform exists in the present catalog; it does not prove that every device, fastener, material, or scenario discussed here has been factory-tested with that set. During sourcing, compare the catalog configuration with the buyer’s own fastener matrix and application sample. Any changed bit map, material, marking, case, or package should receive a new documented approval rather than inheriting evidence from a previous revision.
When is smart pet feeder motor and sensor service complete and verifiable?
Completion for smart pet feeder motor and sensor service requires more than reinstalling the visible screws. Reconcile all parts, confirm natural alignment and uniform seams, check that cables and moving parts remain clear, verify the required safety or functional state, and record any replaced fastener or deviation. Where the product maker specifies calibration, leak testing, electrical safety verification, or software checks, those steps remain part of completion and may require qualified equipment. A clean exterior cannot substitute for those controls, and this guide does not expand a user’s authorized service boundary.
A feeder repair succeeds only when mechanical dispensing, sensor response, cleanability, and enclosure fastening are all restored. The practical engineering insight for smart pet feeder motor and sensor service is to preserve information and geometry before adding force. This guide was prepared from the present XOENAEN catalog record, the cited official safety or quality resources, and the specific mechanical factors stated in each section. No unpublished certification, laboratory result, customer case, or universal compatibility claim is assumed. The recommended decision is to validate the selected manual screwdriver platform with the exact fasteners and assembly conditions before purchase, repair rollout, or mass-production approval.
Manual Screwdriver Planning for Smart Pet Feeder Service: practical option comparison
| Option | Appropriate use | Decision limit |
|---|---|---|
| Food-zone hand tools | Approved removable bowls and guards | Must follow cleaning compatibility |
| Precision electronics set | Motor, sensor, and control housing | Must remain dry and clean |
| General household driver | Available for large outer screws | Can contaminate food-contact areas |
- Confirm the exact customer question for smart pet feeder motor and sensor service: Which manual screwdriver workflow protects a smart pet feeder motor, bowl sensor, battery door, and food-contact areas?
- Map power removal, food residue, motor preload, sensor alignment, cable routing, and washable-part boundaries on representative assemblies.
- Approve the complete profile, size, and shaft-reach list for smart pet feeder motor and sensor service.
- Verify handle leverage and holder stability without overriding this stop rule: moisture reaches electronics, a battery is damaged, or the gear preload is undocumented.
- Check bit labels, case retention, replenishment, and revision identity for the 128-in-1 manual screwdriver set.
- Define a sample method, observations, and acceptance decision for smart pet feeder motor and sensor service.
- Keep packaging, listing, manual, and delivered-SKU claims synchronized.
- 128-in-1 manual screwdriver set product details →
- Compare all XOENAEN product families →
- Plan an OEM or private-label tool project →
- Review manufacturing and quality controls →
- Read XOENAEN tool and sourcing FAQs →
- Manual Screwdriver Workflow for Sim Racing Controller Service →
- Manual Screwdriver Guide for Irrigation Controller Panel Service →
- How XOENAEN presents quality evidence →
What must be confirmed before smart pet feeder motor and sensor service begins?
Confirm power removal, food residue, motor preload, sensor alignment, cable routing, and washable-part boundaries first. For smart pet feeder motor and sensor service, the job should remain inside the documented service or assembly boundary, with the workpiece supported and every fastener position identified before the first turn.
Which screwdriver feature matters most for smart pet feeder motor and sensor service?
Exact recess engagement matters most for smart pet feeder motor and sensor service. Handle size, shaft reach, and case organization should then support the access and control described by this task: Compatible cleaning, motor and gear position, sensor brackets, battery safety, gasket placement, plastic-boss condition, and separation of washable and electronic parts govern tool handling.
When should a technician stop smart pet feeder motor and sensor service?
Stop immediately when moisture reaches electronics, a battery is damaged, or the gear preload is undocumented. That condition removes the evidence needed for a controlled decision, so more leverage or repeated turning should not be used as a substitute for diagnosis.
How should removed screws be organized during smart pet feeder motor and sensor service?
Organize screws by exact position and removal layer during smart pet feeder motor and sensor service. Record length, washer or spacer order, and any visually similar fasteners separately so reassembly does not depend on memory or approximate appearance.
Can a large bit count guarantee safe smart pet feeder motor and sensor service?
No, a large bit count cannot guarantee safe smart pet feeder motor and sensor service. The useful set is the one that proves the required profiles, sizes, reach, holder stability, instructions, and replacement path for this specific work.
What should a buyer test when sourcing tools for smart pet feeder motor and sensor service?
Test representative access, recess fit, hand control, organization, and the documented stop rule for smart pet feeder motor and sensor service. The sample review should also confirm Pet-product service kits need cleanable labeled storage, plastic-safe hand control, dry-zone instructions, screw maps, and explicit food-contact boundaries.